Draw the model. Click run. Read the diagrams.


Pre-alpha. Under active development. APIs and file formats will change.
---
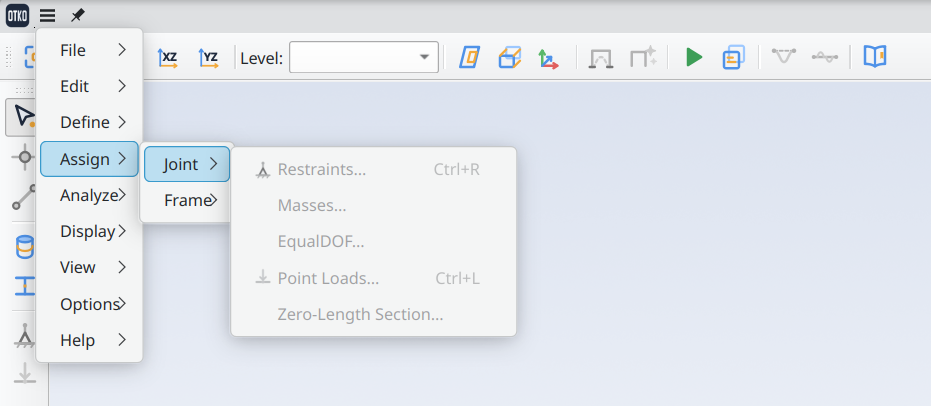 |
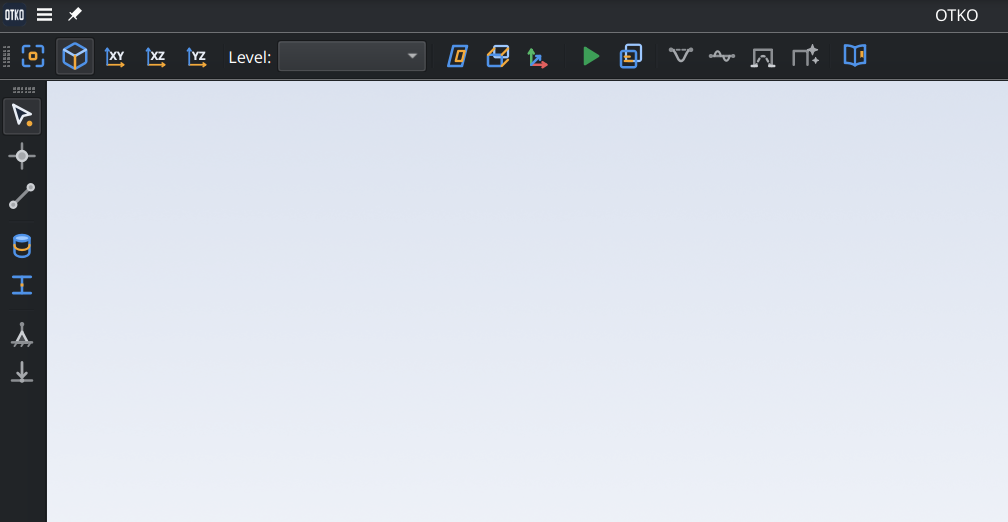 |
 |
| SAP2000-style menus |
Compact dark toolbar |
Parametric grid wizard |
## What is OTKO?
OpenSees does nonlinear FEM well. Its user interface is a script.
OTKO puts a visual front-end on top of it: draw nodes, frames,
supports, and loads on a snapped grid; assign materials, sections,
and load patterns through dialogs; run the analysis with progress
and cancel; then read the results — deformed shapes, mode shapes,
force diagrams, pushover curves, hysteresis loops.
Underneath, the `core` Pydantic model works fine from a script or
notebook without any GUI. The GUI is a front-end, not the whole
product.
## Highlights
| Area | What you get |
| ---- | ------------ |
| **Modeling** | Grid wizards, nodes, frames (elastic + force-based), trusses, quads, zero-length sections, restraints, equalDOF constraints, distributed loads, ground motions (`PathTimeSeries` / `UniformExcitation`). |
| **Materials & sections** | `Steel01`, `Steel02`, `Concrete01`, `Concrete02`, `ElasticPP`, `Hysteretic`, fiber sections (rectangular / circular patches + rebar), `SectionAggregator`, `BeamWithHinges`. |
| **Analysis** | Static (load- or displacement-controlled), modal, pushover, transient time-history with mode-1 Rayleigh damping. Chained workflows: gravity preload → `loadConst -time 0.0` → pushover or transient. |
| **Post-processing** | Deformed shape with scale slider, animated mode shapes, axial / shear / moment diagrams, pushover curves, time-history plots, hysteresis loops, response-spectrum SRSS / CQC, snapshot + video export. |
| **Persistence** | One Pydantic-validated `.osmodel` JSON per project — diffs cleanly in Git, builds cleanly from Python. Analysis output in HDF5 (`*.osresults.h5`). |
20+ verified examples ship with the repo, including OpenSees Wiki
Examples 1–4 and a fiber-section RC frame pushover. See
[`examples/README.md`](examples/README.md).
## Quick start
```bash
git clone ssh://git@smill-home.ddns.net/smill/otko.git
cd otko
python -m venv .venv
.venv\Scripts\activate # Windows
source .venv/bin/activate # Linux / macOS
pip install -e ".[gui,dev]" # desktop: Qt + PyVista + dev tools
# pip install -e . # headless: core + services only
python -m otko
```
Then:
1. **File → Open** → `examples/cantilever.osmodel`.
2. **Analyze → Cases** → run `Tip-Load`.
3. **Display → Show Force Diagram** → **M3**: 50 kN·m at the fixed end.
**V2**: constant −10 kN.
4. **Display → Show Deformed Shape** → the cantilever curve.
Nonlinear version: open `examples/portal_pushover.osmodel`, run
`Push-X`, **Display → Show Pushover Curve** — elastic ramp, then a
yield plateau as the base hinges form.
Python 3.10+. On Windows use **3.12+** — `openseespywin==3.8.0.0`
has no 3.11 wheel (`Requires-Python >=3.12`). Both pins already
live in `pyproject.toml`.
## Architecture
Strict MVVM + service layer, one direction only:
```
views (Qt) → viewmodels → services (OpenSeesRunner, Persistence) → core (model)
```
`core` is pure Python — no Qt, no OpenSeesPy imports — and unit-tests
in isolation. PySide6 + PyVista on the view, pyqtgraph for 2D plots,
Pydantic v2 for the model, h5py for results. Long version, including
the OpenSeesPy command order the runner emits, in
[`docs/architecture.md`](docs/architecture.md).
## Roadmap
[`docs/roadmap.md`](docs/roadmap.md) has the phase-by-phase plan.
Phases 0–7 (modeling, analysis, post-processing) are mostly done.
Phase 8 — isolators, ground-motion library, IDA, fiber-section
editor polish — is where the open work is.
## Contributing
Collaborators welcome — most useful to people who already work with
OpenSees and want a shorter path from idea to model:
- **Structural / earthquake engineers** who can tell us when a feature
is almost right but not quite.
- **Researchers** running pushover, IDA, or response-spectrum studies
against hand-built scripts.
- **Python / Qt developers** into scientific desktop apps, VTK
rendering, or Pydantic schema design.
- **Students** learning FEM and GUI architecture — the examples and
tests are meant to read as documentation.
- **UX / icon designers** willing to argue about dialogs and toolbars.
Bug reports and reproducible test cases count as contributions. Setup
and the rules enforced in review: [`CONTRIBUTING.md`](CONTRIBUTING.md).
Test suite:
```bash
pytest tests/unit # pure logic, milliseconds
pytest tests/gui # Qt event-loop tests (pytest-qt)
pytest tests/integration # real OpenSeesPy runs on bundled examples
```
CI runs lint + the non-`slow` subset on Linux / macOS / Windows
× Python 3.10 / 3.11 / 3.12.
## License
OTKO is **GNU Affero General Public License v3.0**
([`LICENSE`](LICENSE)). In short:
- Research, education, personal projects: fine, keep the copyright
notice.
- Fork and modify: fine.
- Distribute it (modified or not): release your full source under
AGPL-3.0.
- Run a modified version as a network service: release your
modifications under AGPL-3.0.
Commercial forks stay open. If you need a different arrangement
(e.g. a closed-source commercial license), open an issue.
Copyright © 2026 Ozan and contributors.